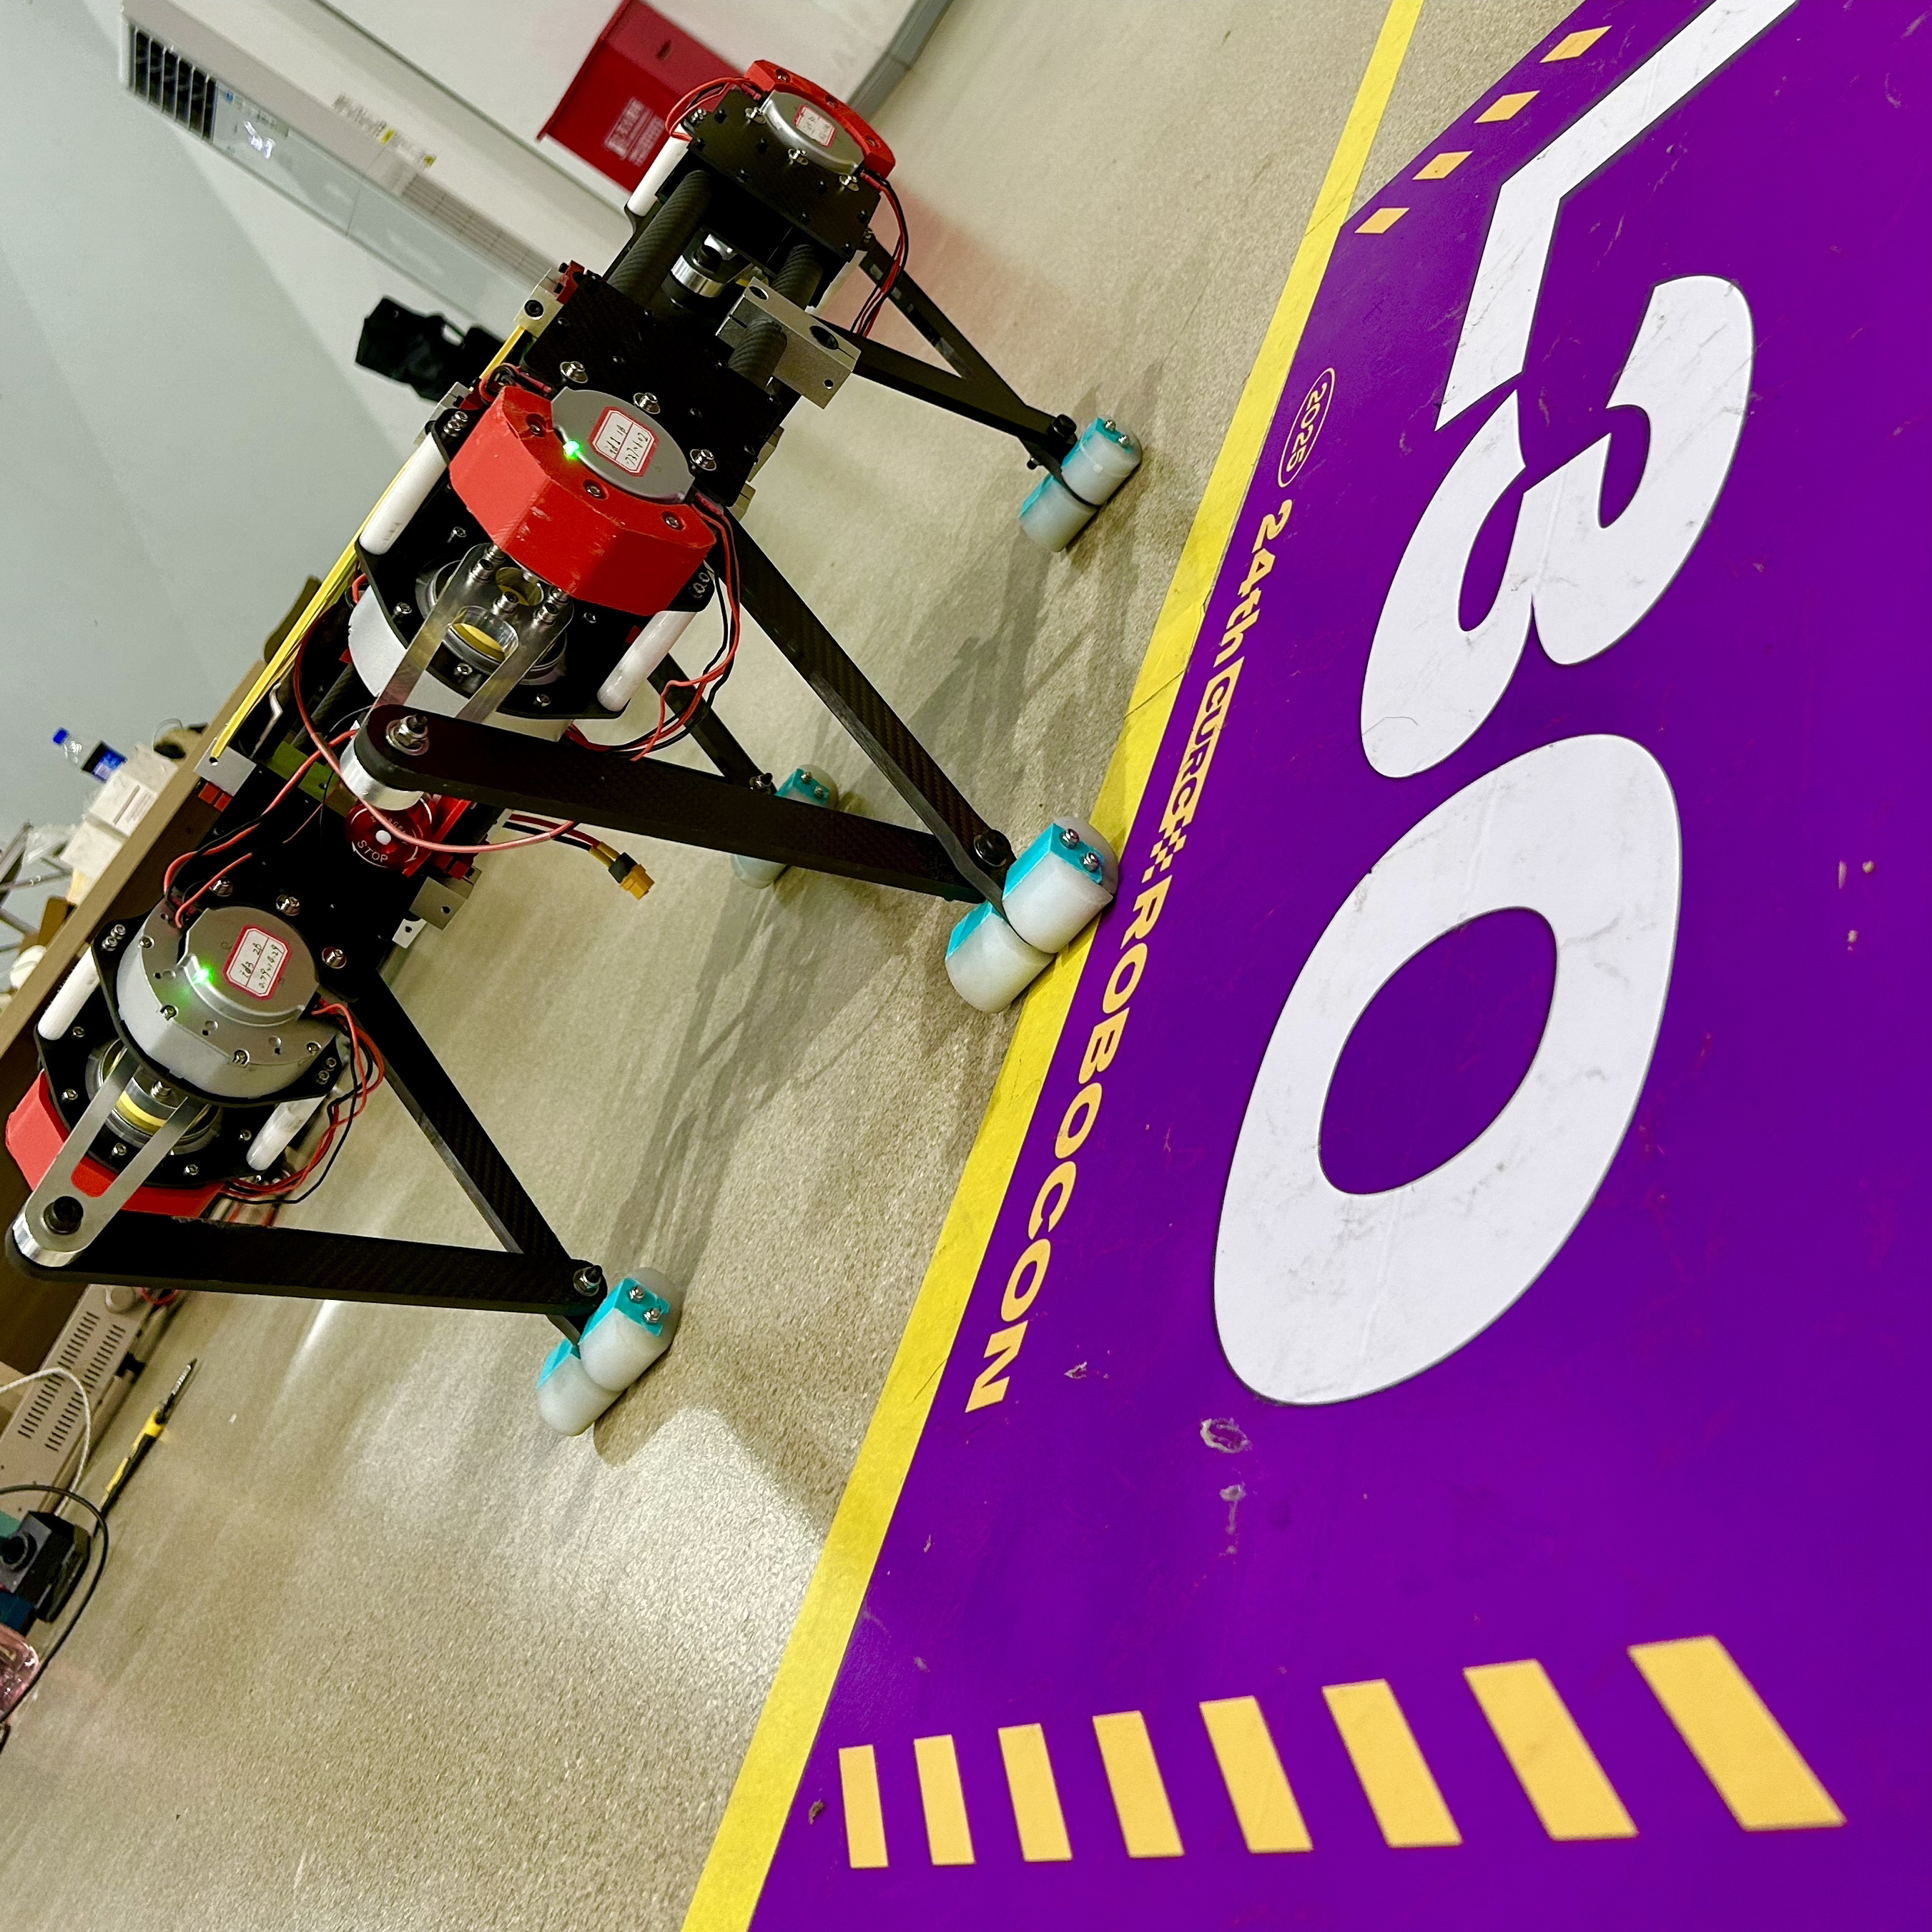
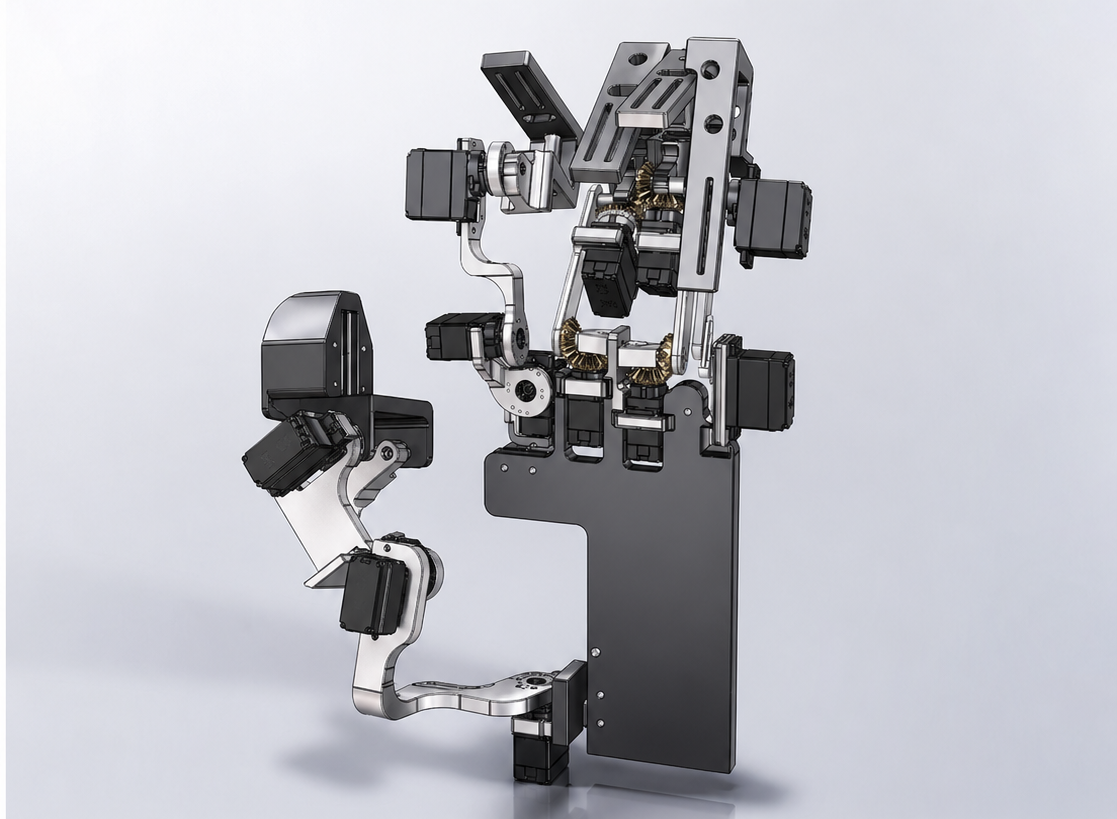
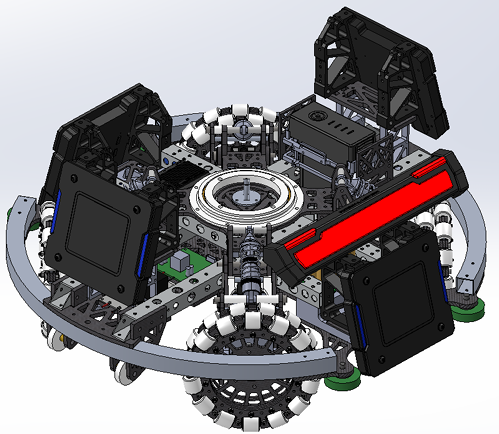
work 8-DOF Parallel Quadruped Robot A lightweight parallel robot based on a kite-shaped four-bar linkage mechanism; received a national-level Innovation and Entrepreneurship Training Program grant. 12-DOF Quadruped Robot (Latest) The first quadruped robot in CURC to achieve knee-elbow conversion via rigid linkages. New Energy Cam-Steering Vehicle with Precise Trajectory An electric vehicle powered by temperature difference, featuring a high-precision cam-steering mechanism. XHand Exoskeleton Based on the open-source project DexUMI, with the core goal of implementing teleoperation (master-slave) conversion via DAgger. Other Research & Competition Projects Some small designs from the ROBOCON competition and other personal work. fun Omnidirectional Mobile Robot Platform Infantry in RoboMaster.A flexible mobile platform based on Mecanum wheels, supporting complex path planning. Replication of "AmazingHand" based on STM32 Mechatronics course design project, in progress.